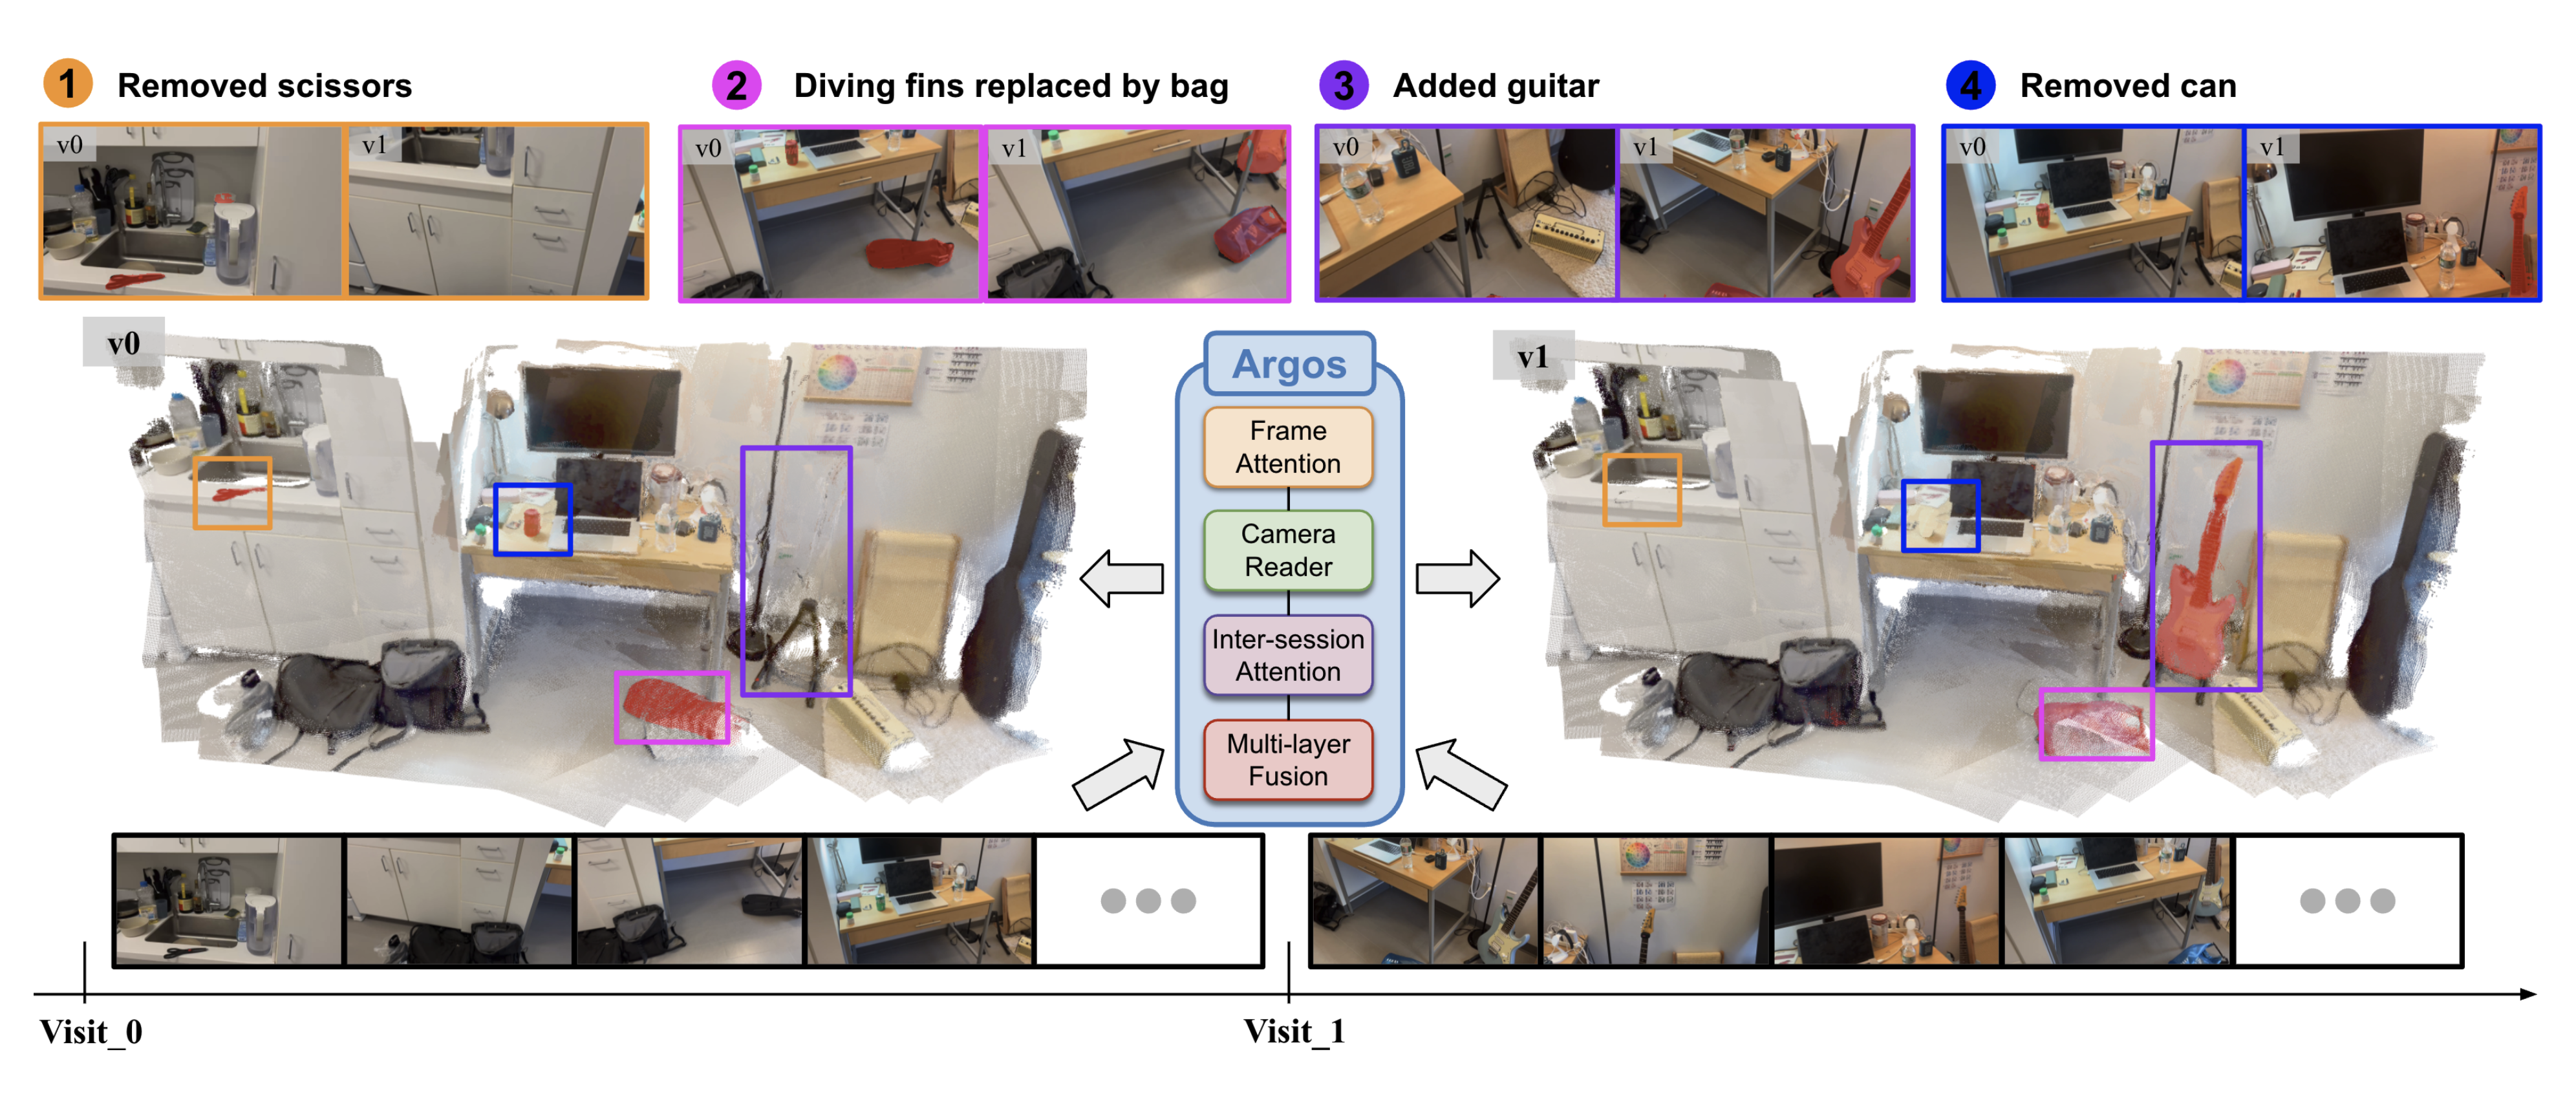
@article{xu2026argos,author={Xu, Ruihan and Yoon, Jiae and Zhou, Kaichen and Kim, Ue-Hwan and Carlone, Luca},title={Argos: Adapt Rich Geometric Priors for Generalizable Online Scene-Change-Detection},journal={arXiv preprint arXiv:2610.10181},year={2026},}
RA-L
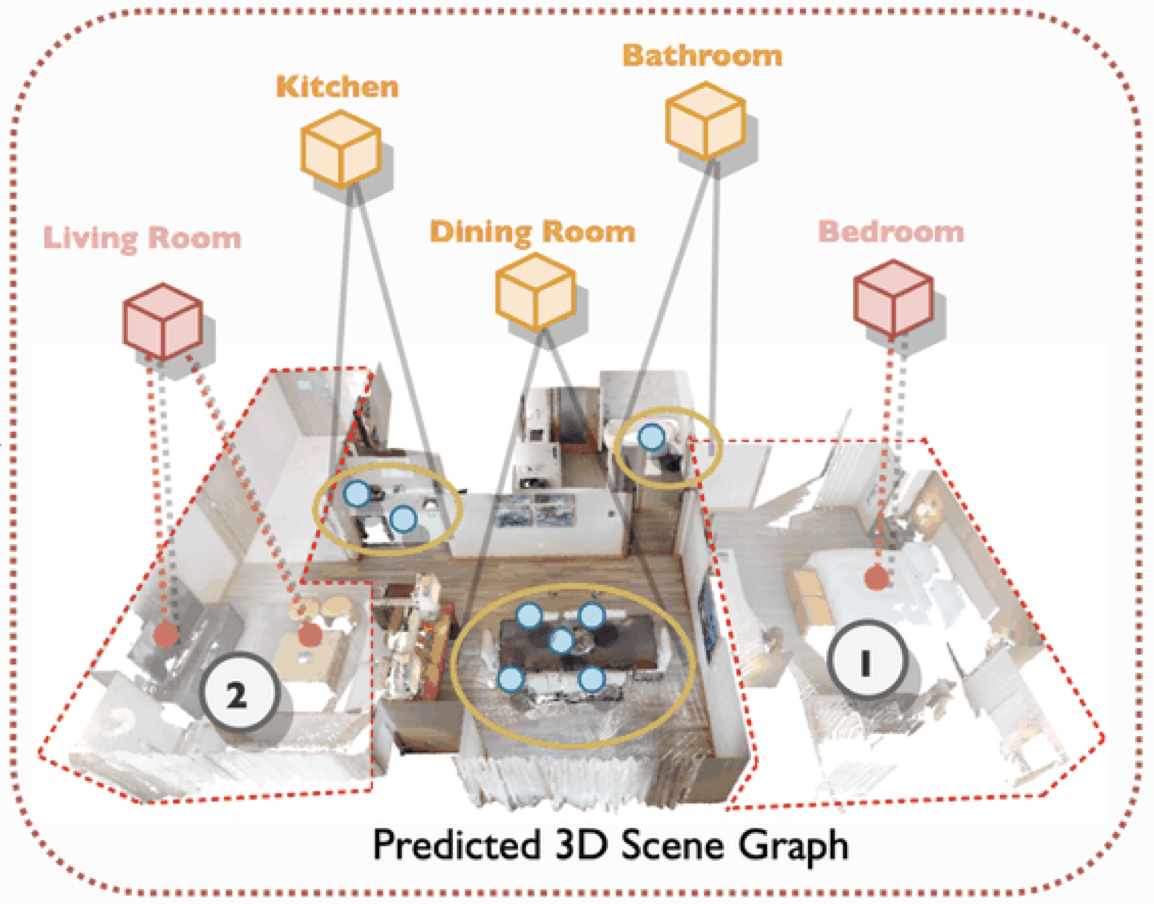
Imaginative World Modeling With Scene Graphs Via VLM for Object Navigation
@article{hu2026imaginative,author={Hu, Yue and Wu, Junzhe and Xu, Ruihan and Liu, Hang and Xi, Avery and Liu, Henry X. and Vasudevan, Ram and Ghaffari, Maani},journal={IEEE Robotics and Automation Letters},title={Imaginative World Modeling With Scene Graphs Via {VLM} for Object Navigation},year={2026},note={to appear},}
IROS
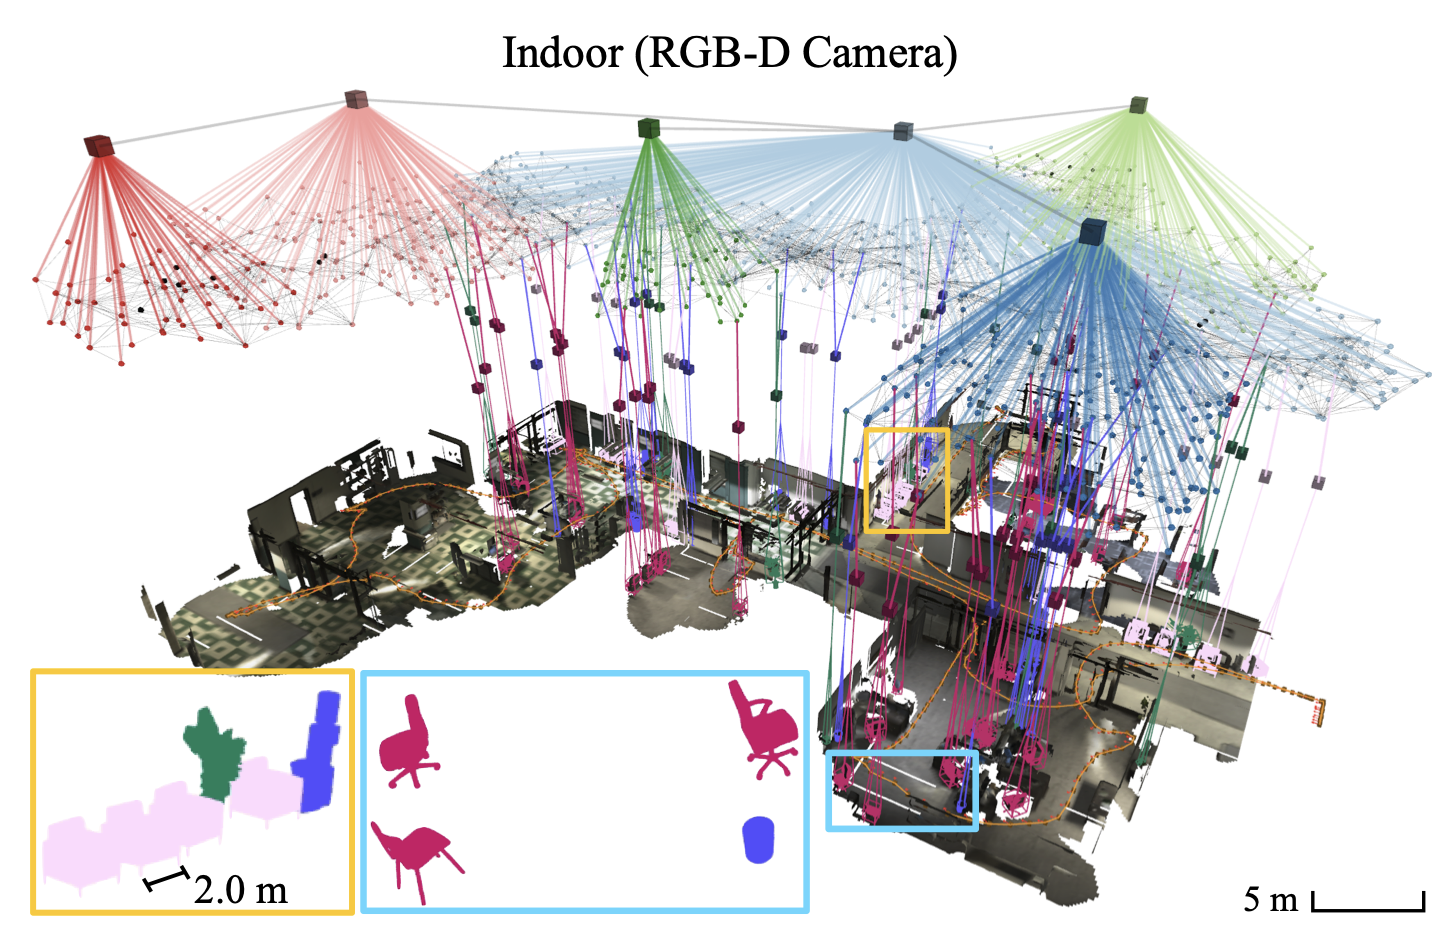
Hydra++: Real-Time Hierarchical 3D Scene Graph Construction With Object-Level Shape Estimation
Hyungtae Lim, Nathan Hughes, Xihang Yu, and 5 more authors
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
@inproceedings{lim2026hydra,author={Lim, Hyungtae and Hughes, Nathan and Yu, Xihang and Xu, Ruihan and Chang, Yun and Shi, Jingnan and Talak, Rajat and Carlone, Luca},title={Hydra++: Real-Time Hierarchical 3D Scene Graph Construction With Object-Level Shape Estimation},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},note={to appear},}
2025
RA-L
LatentBKI: Open-Dictionary Continuous Mapping in Visual-Language Latent Spaces With Quantifiable Uncertainty
Joey Wilson*, Ruihan Xu*, Yile Sun, and 4 more authors
@article{10876603,author={Wilson, Joey and Xu, Ruihan and Sun, Yile and Ewen, Parker and Zhu, Minghan and Barton, Kira and Ghaffari, Maani},journal={IEEE Robotics and Automation Letters},title={LatentBKI: Open-Dictionary Continuous Mapping in Visual-Language Latent Spaces With Quantifiable Uncertainty},year={2025},volume={10},number={4},pages={3102-3109},keywords={Uncertainty;Semantics;Robots;Kernel;Neural networks;Bayes methods;Probabilistic logic;Three-dimensional displays;Smoothing methods;Visualization;Mapping;semantic scene understanding;deep learning for visual perception},doi={10.1109/LRA.2025.3539091},}
2024
RSS Workshop
Single-View 3D Reconstruction via SO(2)-Equivariant Gaussian Sculpting Networks
Ruihan Xu, Anthony Opipari, Joshua Mah, and 4 more authors
In RSS 2024 Workshop on Geometric and Algebraic Structure in Robot Learning, 2024
@inproceedings{xu2024soequivariant,title={Single-View 3D Reconstruction via {SO}(2)-Equivariant Gaussian Sculpting Networks},author={Xu, Ruihan and Opipari, Anthony and Mah, Joshua and Lewis, Stanley Robert and Zhang, Haoran and Guo, Hanzhe and Jenkins, Odest Chadwicke},booktitle={RSS 2024 Workshop on Geometric and Algebraic Structure in Robot Learning},year={2024},url={https://arxiv.org/abs/2409.07245},}
RA-L
Stein Variational Belief Propagation for Multi-Robot Coordination
Jana Pavlasek, Joshua Jing Zhi Mah, Ruihan Xu, and 2 more authors
@article{10465621,author={Pavlasek, Jana and Mah, Joshua Jing Zhi and Xu, Ruihan and Jenkins, Odest Chadwicke and Ramos, Fabio},journal={IEEE Robotics and Automation Letters},title={Stein Variational Belief Propagation for Multi-Robot Coordination},year={2024},volume={9},number={5},pages={4194-4201},keywords={Robots;Robot kinematics;Belief propagation;Trajectory;Planning;Collision avoidance;Service robots;Distributed robot systems;probabilistic inference},doi={10.1109/LRA.2024.3375708},}